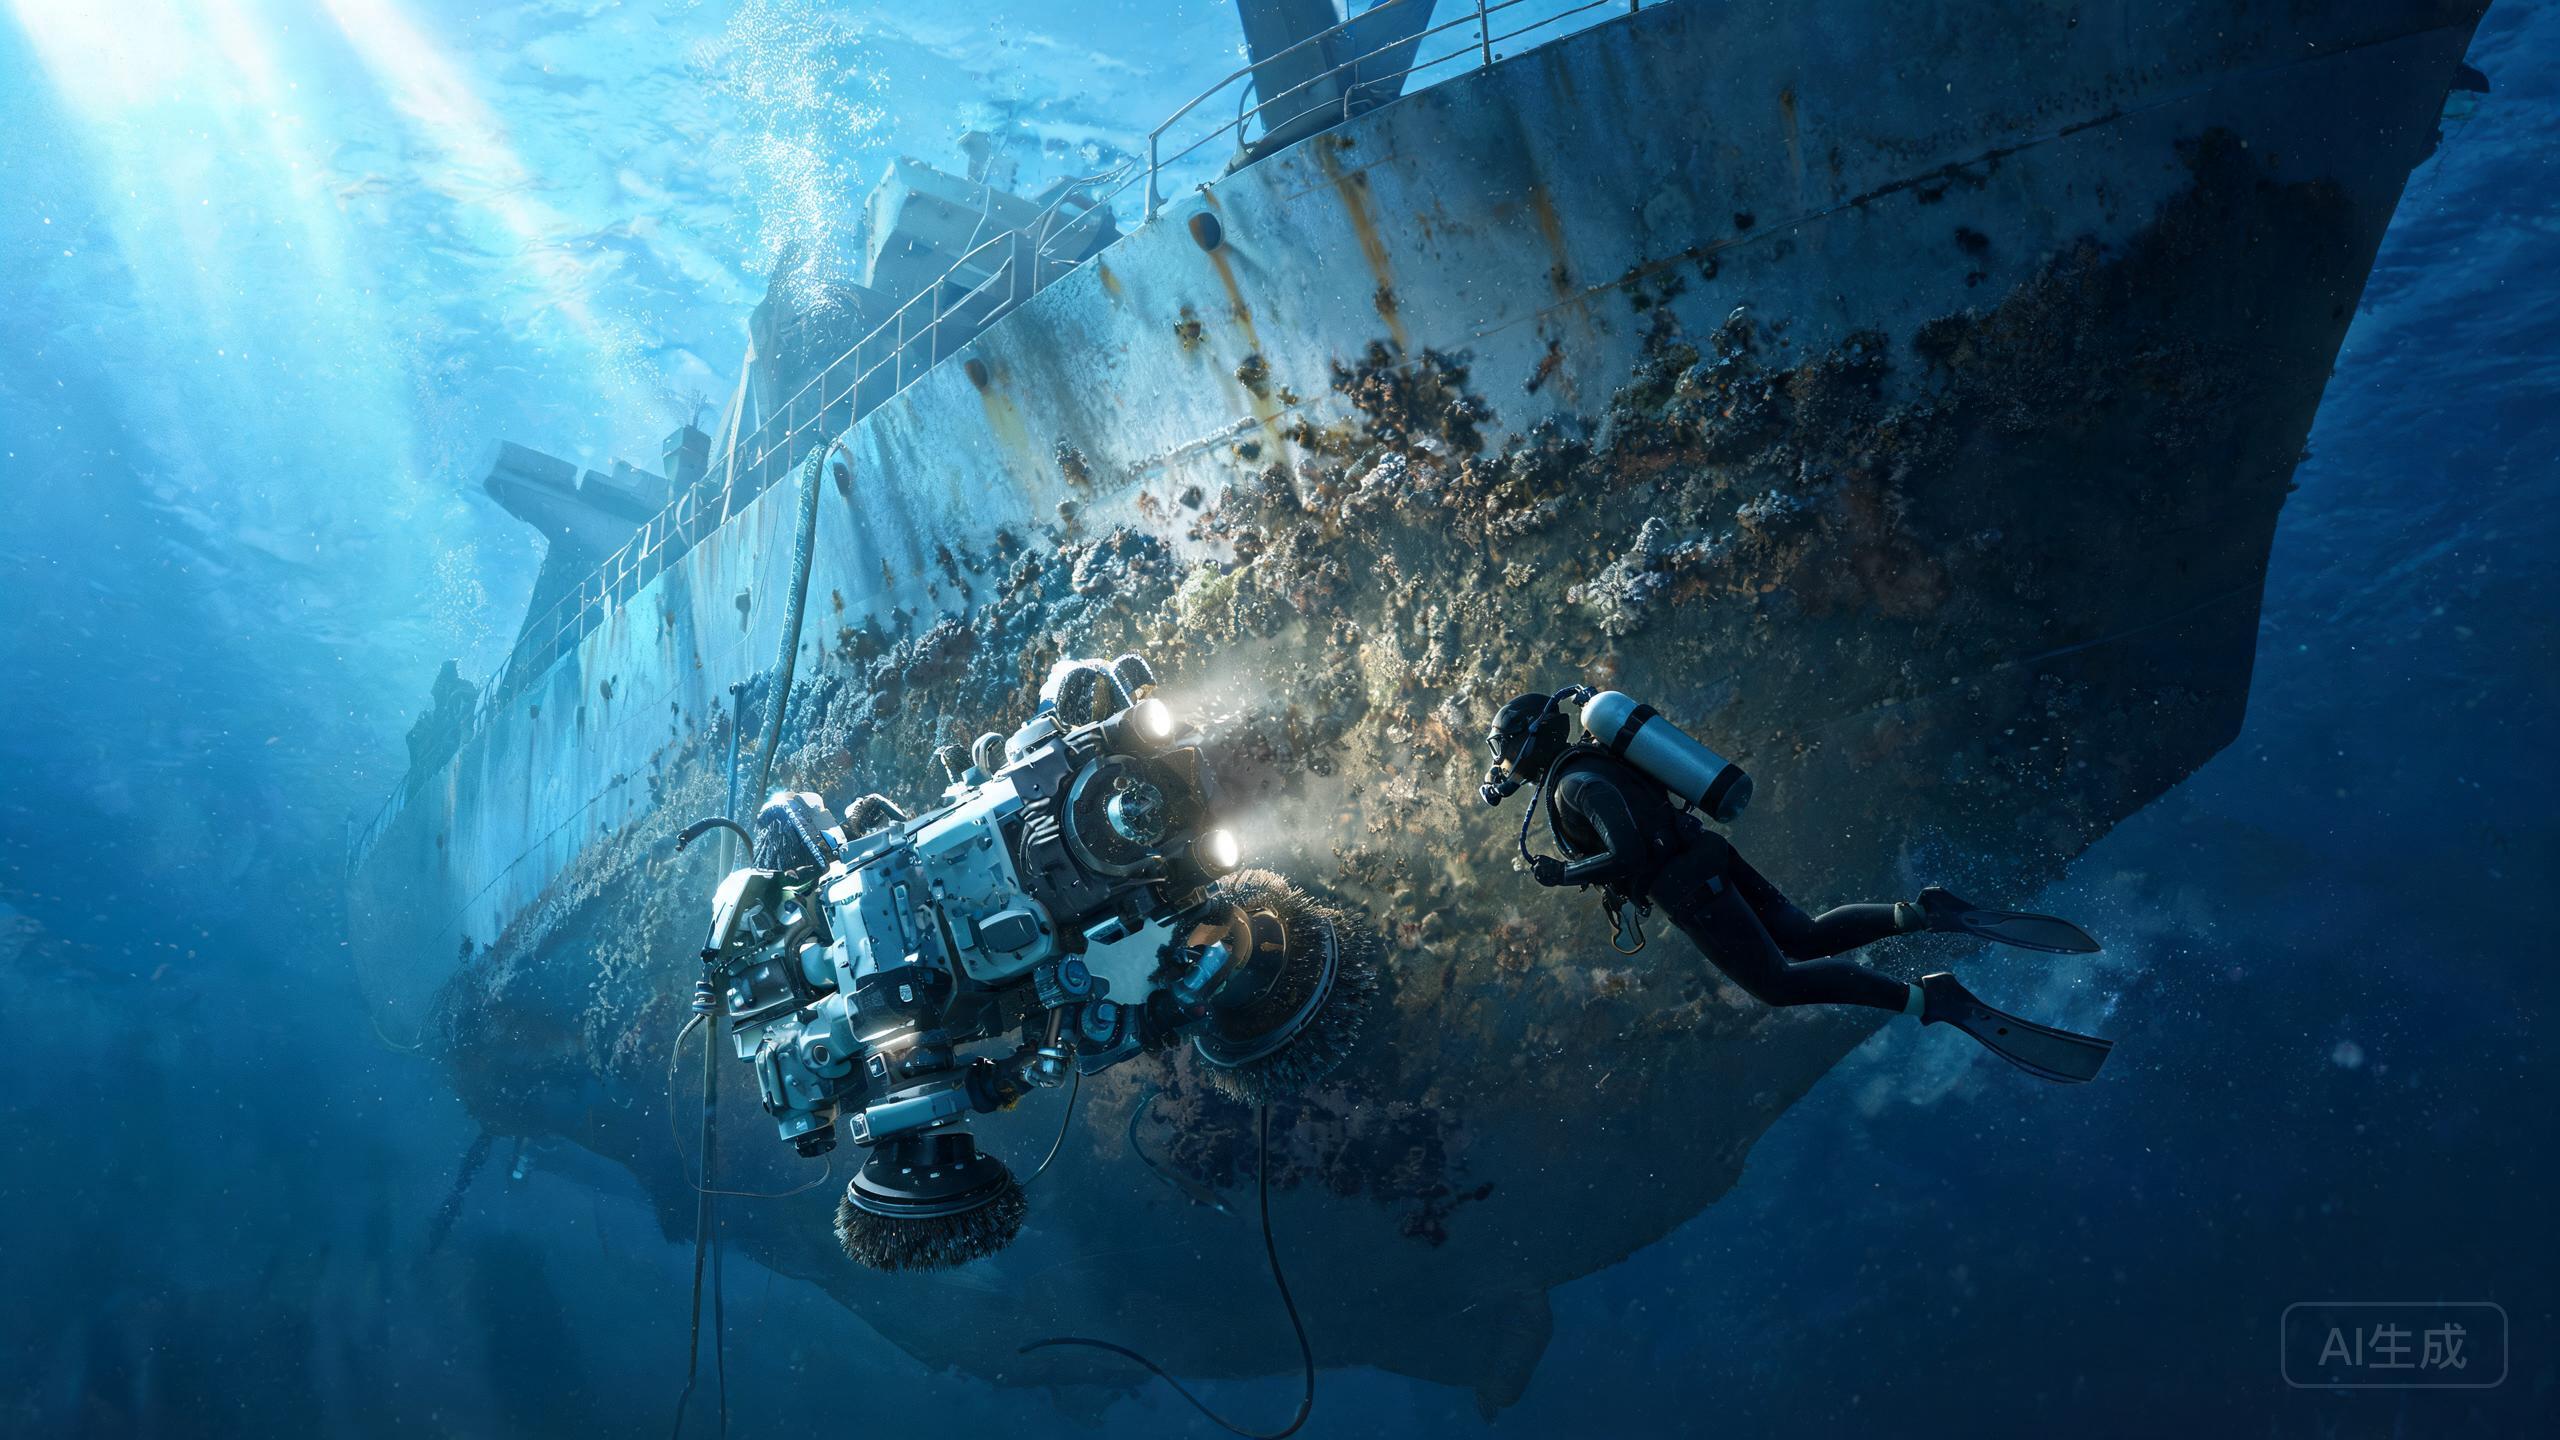
If you have already read our investment, coverage, and operational-reality articles, this guide takes a different angle: the actual setup and installation workflow. The Fleet Robotics Hull Cleaning Robot is a magnetic hull crawling robot rated at 8.5/10, designed for steel hulls with modular tooling and coverage up to 400 m²/h. Below is a practical, step-by-step path from crate to first cleaning pass, written for ship crews and technical superintendents planning an underwater hull cleaning robot 2026 deployment.
Pre-Installation Checks Before the Robot Touches the Water
Before any launch, confirm your vessel meets the platform's core requirement: steel hulls only. The magnetic adhesion system will not work on aluminum, GRP, or composite hulls, so verify hull material and coating type first. Check that the hull area to be cleaned is free of large debris, loose paint flakes, and active anode protrusions that could obstruct the magnetic hull crawling robot. Prepare a clean, dry staging area on deck or at the dock with enough space to lay out the robot, its modular tooling, and tether or control lines. Confirm power availability and that the control station is positioned with a clear line of sight to the launch point.
Unboxing, Assembly, and Modular Tooling Setup
Unpack the robot and inspect for shipping damage, especially around the magnetic adhesion modules and drive components. Because the tooling is modular, decide which cleaning head matches your hull condition before assembly. Light biofouling may need a softer brush, while heavier calcareous growth typically calls for a more aggressive attachment. Mount the selected tooling according to the manufacturer's instructions, then hand-check every fastener and connection. If your ship hull cleaning drone review notes from other operators mention specific tooling for certain hull classes, use that as a starting reference, but always confirm against your own coating spec. Charge or connect the control unit and run a dry bench test to confirm all motors and sensors respond before the unit goes near water.
Launch Sequence and Magnetic Adhesion Verification
Lower the robot into the water at the launch point and let it stabilize. Engage the magnetic adhesion system and verify it holds firmly against the steel hull before commanding any movement. This step is critical: a magnetic hull crawling robot that loses grip can drift or fall, so test adhesion at multiple spots along the hull. Once adhesion is confirmed, run a short controlled pass at reduced speed to observe tracking and tooling behavior. Only after a stable low-speed pass should you increase toward the rated coverage of up to 400 m²/h. Keep the control station manned throughout and maintain communication with any dive or surface support team.
First-Pass Optimization and Operational Handover
After the first full pass, review coverage patterns and tooling wear. Adjust speed, overlap, and tooling choice based on actual biofouling removal rather than assumptions. Document the settings that worked for your hull, because repeatability matters when comparing a ROV hull cleaner vs diver teams over a season. If fuel savings are a key goal, track hull condition before and after cleaning so you can later correlate hull cleaning fuel savings with the robot's performance. Train at least two operators on launch, adhesion checks, and emergency retrieval so the system is not dependent on a single person. Finally, set a maintenance interval for the magnetic modules and modular tooling based on the manufacturer's guidance and your actual usage.
Our verdict
Setting up the Fleet Robotics Hull Cleaning Robot is less about complex installation and more about disciplined verification: confirm steel hulls, build the modular tooling correctly, prove magnetic adhesion before movement, and optimize from real first-pass data. At a rating of 8.5/10 with up to 400 m²/h coverage, the platform rewards crews who treat setup as a repeatable procedure. Do that, and your biofouling cleaning robot cost analysis becomes far more accurate, because you are measuring a properly commissioned system rather than a hastily launched one.