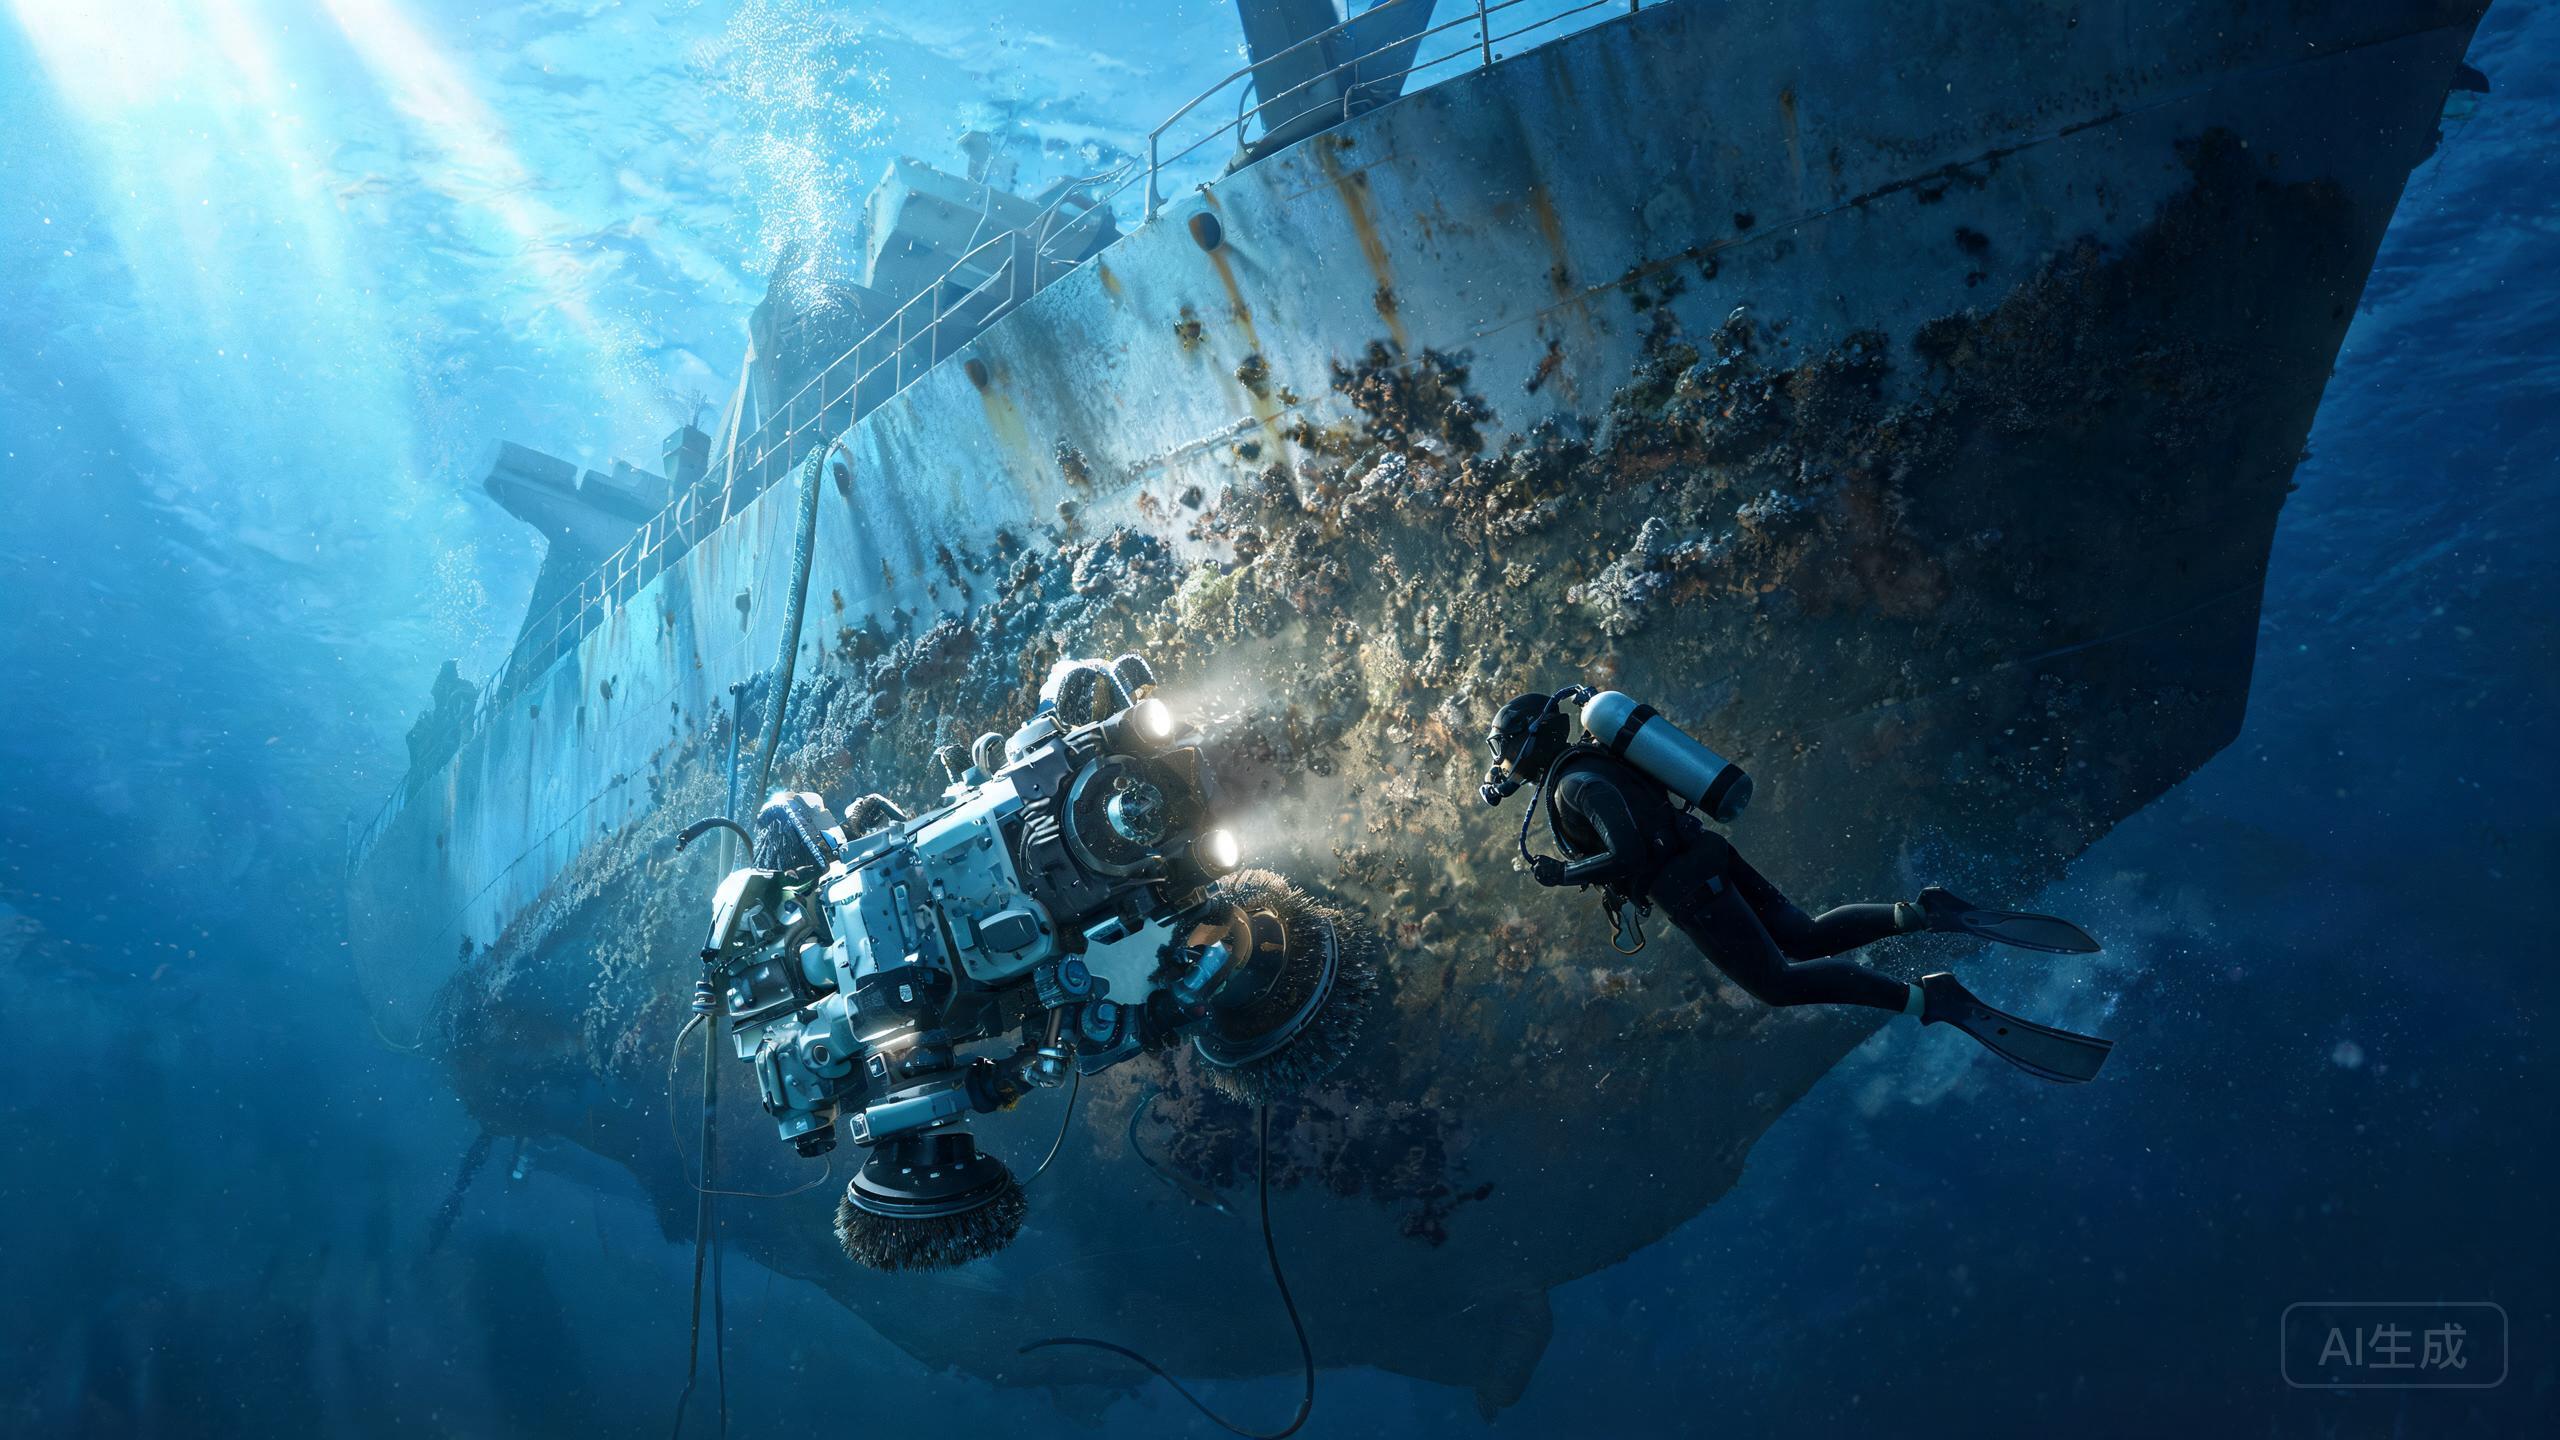
Even a well-rated magnetic hull crawling robot can hit snags on the dock. This guide skips the sales pitch and setup basics already covered elsewhere. Instead, it walks through the most common field problems reported by crews running the Fleet Robotics Hull Cleaning Robot in 2026, from adhesion drop-offs to uneven coverage, and gives practical fixes. If you are comparing a ship hull cleaning drone review against diver teams, or weighing biofouling cleaning robot cost against hull cleaning fuel savings, these troubleshooting steps help you keep the platform productive rather than idle.
Why Magnetic Adhesion Weakens Mid-Pass (and How to Recover)
The most frequent complaint about any magnetic hull crawling robot is a sudden loss of grip or a slow slide on vertical surfaces. On the Fleet Robotics unit, adhesion is magnetic and tuned for steel hulls, so the first check is surface condition: thick paint build-up, heavy calcareous fouling, or weld seams can lift the platform slightly and reduce holding force. Clean the track contact area and slow the pass rate over rough zones. Second, confirm you are actually on steel — this platform is steel-hull optimized and will not hold on aluminum or composite. Third, inspect the magnetic modules for trapped debris or corrosion between passes. If the robot still slips, reduce speed and split the hull into smaller passes rather than forcing continuous 400 m²/h runs across awkward geometry.
Uneven Coverage: Diagnosing Gaps in the 400 m²/h Claim
Coverage figures assume ideal conditions; real passes often leave streaks. If you notice missed bands, check three things before blaming the machine. Overlap: if your path spacing matches the tool width exactly, slight drift creates gaps — increase overlap by 10–15%. Speed: pushing toward the top of the coverage range on fouled or curved areas causes the tool to skip. Tooling fit: because the platform uses modular tooling, a brush or pad mismatched to the fouling type will clean unevenly. Swap modules for the fouling profile and re-test on a small patch. Documenting actual cleaned area per hour also gives you honest numbers for any ROV hull cleaner vs diver comparison you are building for management.
Modular Tooling Jams and Fouling Build-Up
Modular tooling is a strength until a module jams. The usual cause is marine growth wrapping around rotating parts, especially after cleaning heavily fouled zones. Stop the pass, retrieve the unit, and clear the tool head before restarting — continuing to run a jammed module strains the drive and skews your biofouling cleaning robot cost calculations through extra downtime. Rinse modules with fresh water after each session; salt residue accelerates wear. Keep a spare set of the most-used modules so a jam does not end the day. Track which module types fail fastest on your hull classes and adjust your consumables budget accordingly.
Steel-Only Limits and When to Escalate
Because adhesion is magnetic, the platform is limited to steel hulls — a known trade-off for this less established brand. If a job involves aluminum, composite, or coated non-ferrous surfaces, do not attempt workarounds; the robot will not hold. Escalate to an alternative method. Likewise, if adhesion and coverage problems persist after cleaning contact surfaces, checking tooling, and slowing passes, log the conditions (fouling type, hull zone, speed, module used) and contact support. Consistent documentation turns a vague fault into a fixable case and protects the hull cleaning fuel savings you are counting on from regular grooming.
Our verdict
Most Fleet Robotics Hull Cleaning Robot problems trace back to surface condition, speed discipline, and tooling match — not the platform itself. Keep contact areas clean, respect the steel-hull limit, increase overlap, and maintain modular tools, and the magnetic hull crawling robot stays close to its rated 400 m²/h. Treat troubleshooting as part of your operating routine, and the underwater hull cleaning robot 2026 workflow becomes predictable enough to plan around.